Pre-seed Funding Round led by Fly Ventures and Toyota Ventures
Sep 2026
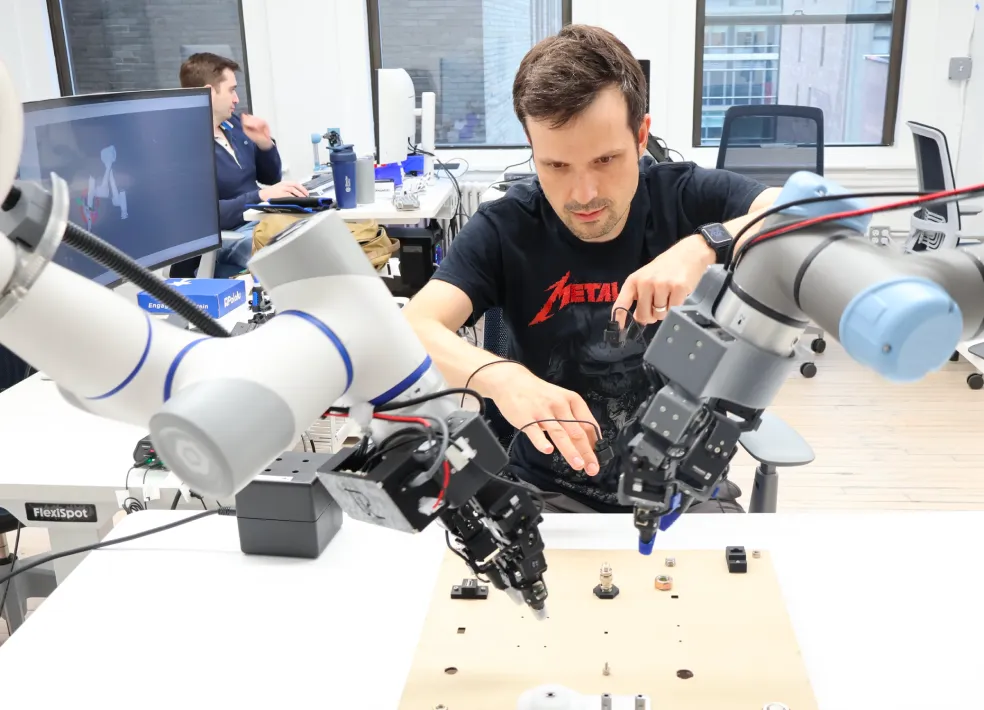
We combine touch sensing, hand design, and motor learning, to build the fine motor skill layer for robotic dexterity and automate complex, high-precision manipulation tasks.
Hands
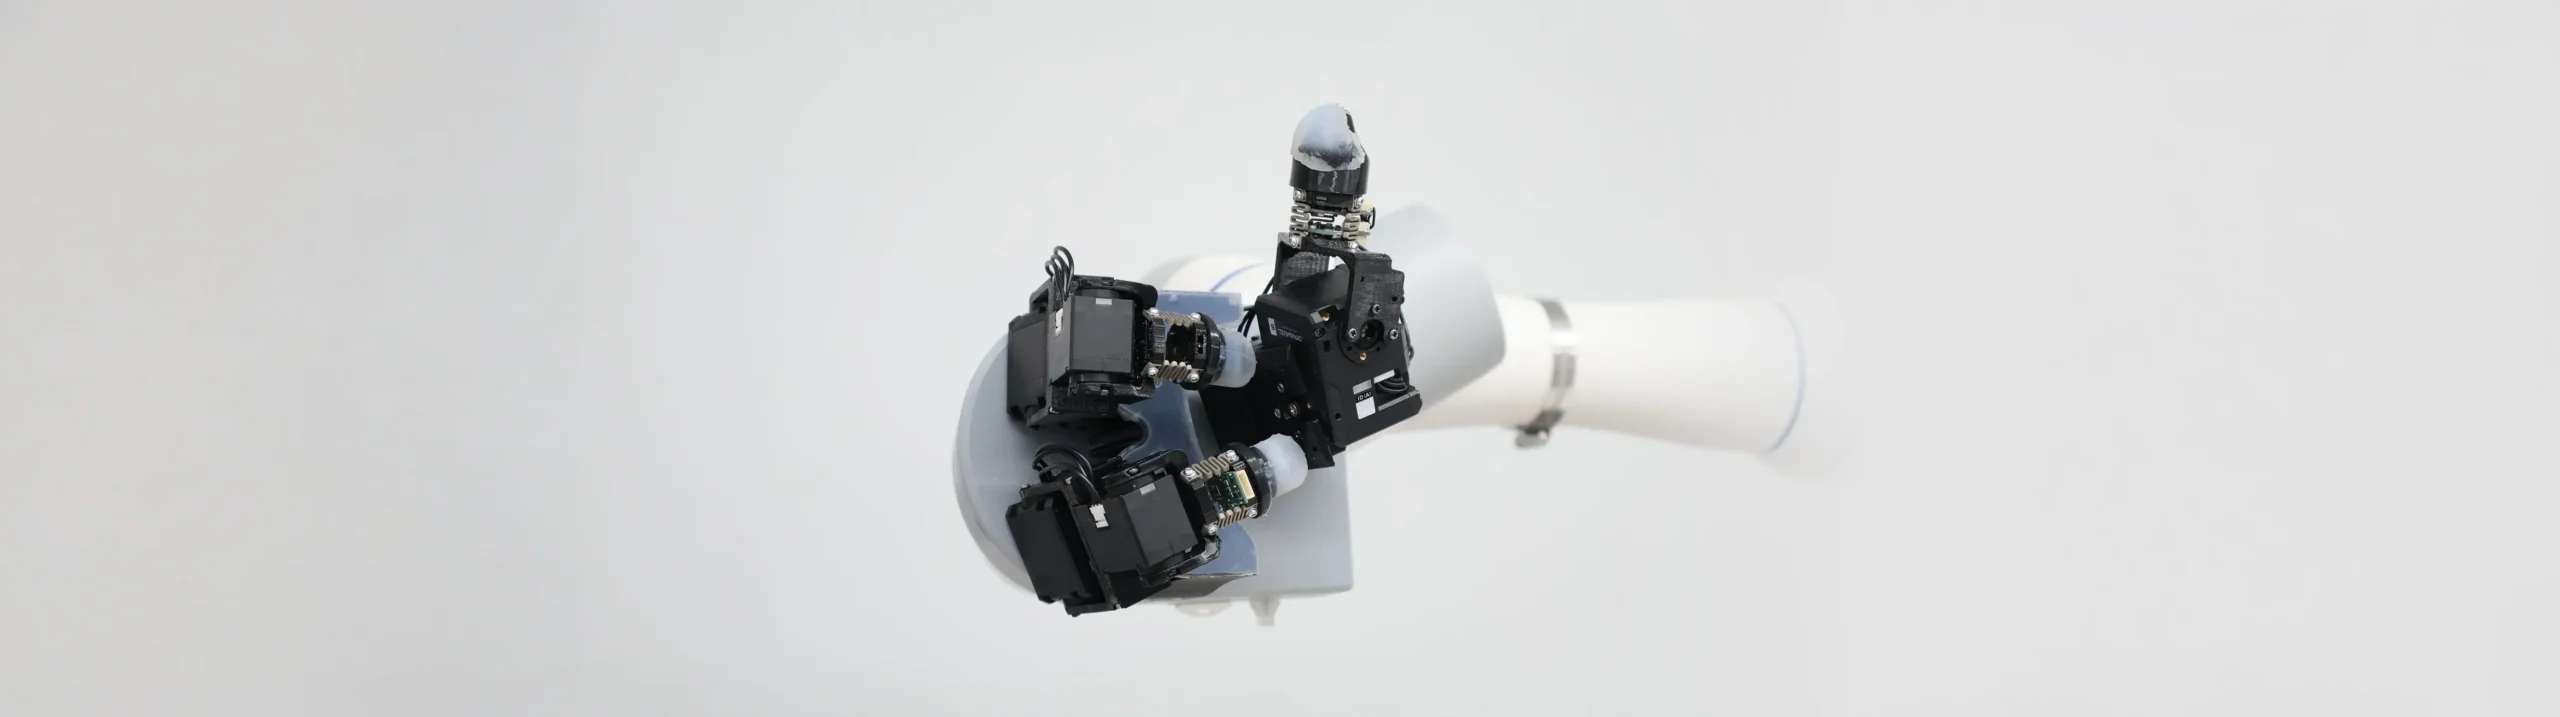
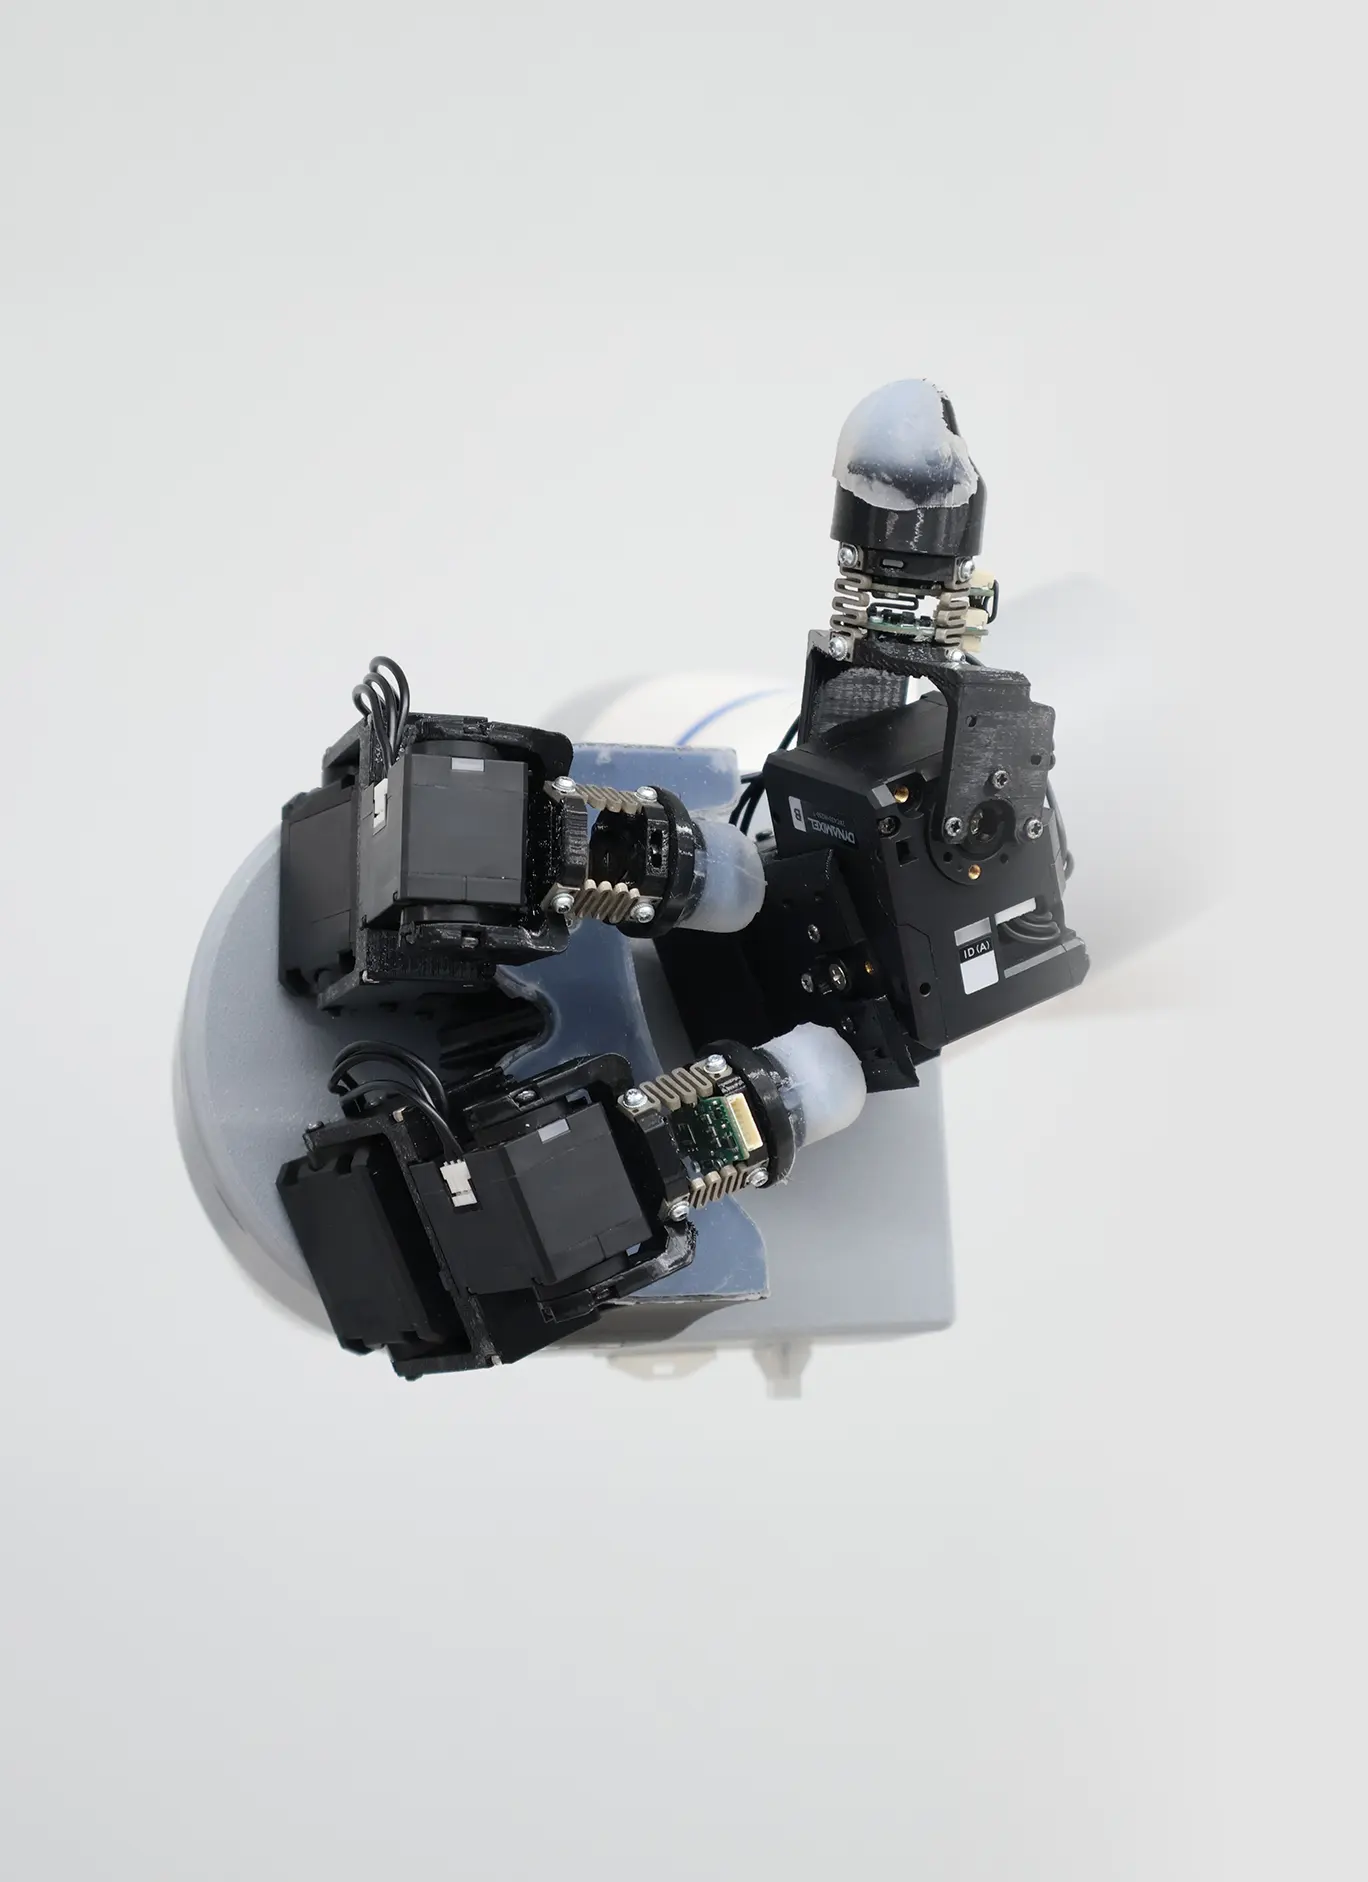
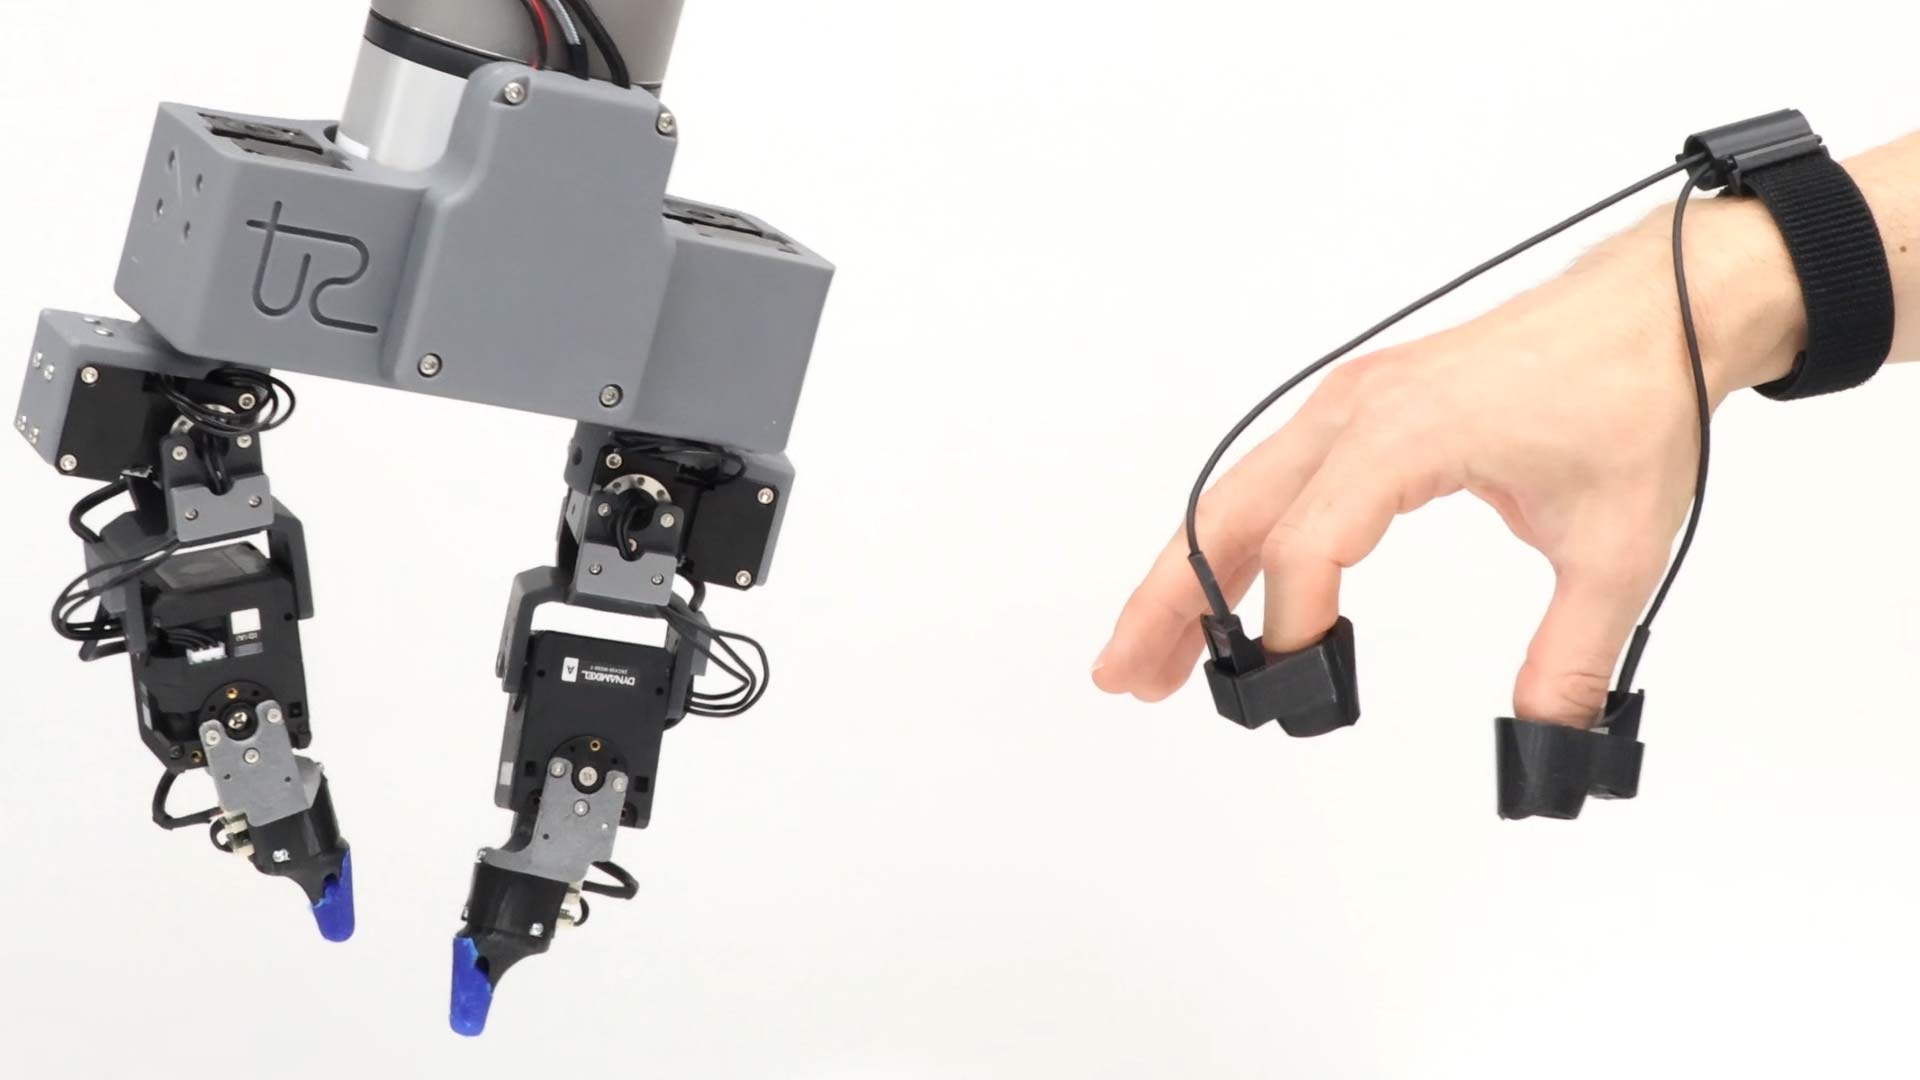
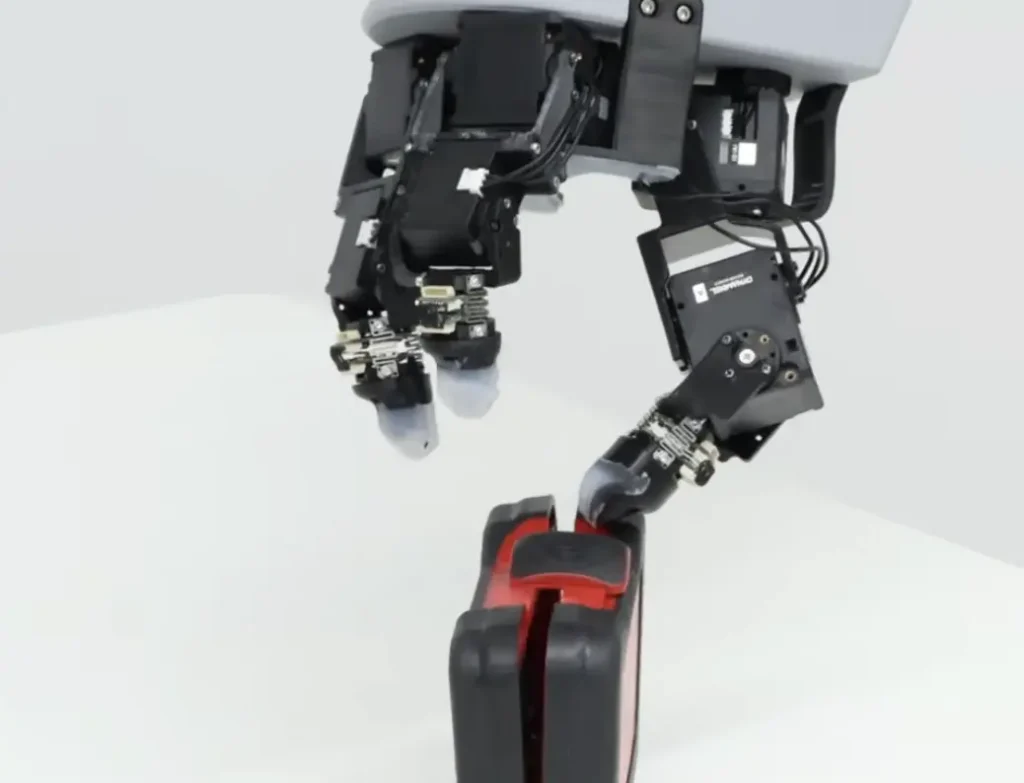
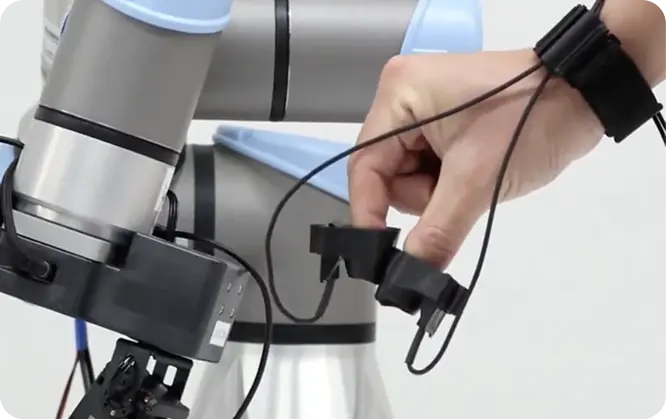
Our hands designs are optimized for multifingered dexterity. They track human fingertip movements without replicating human articulation, enabling dexterous data collection and autonomous policy training for intricate manipulation.
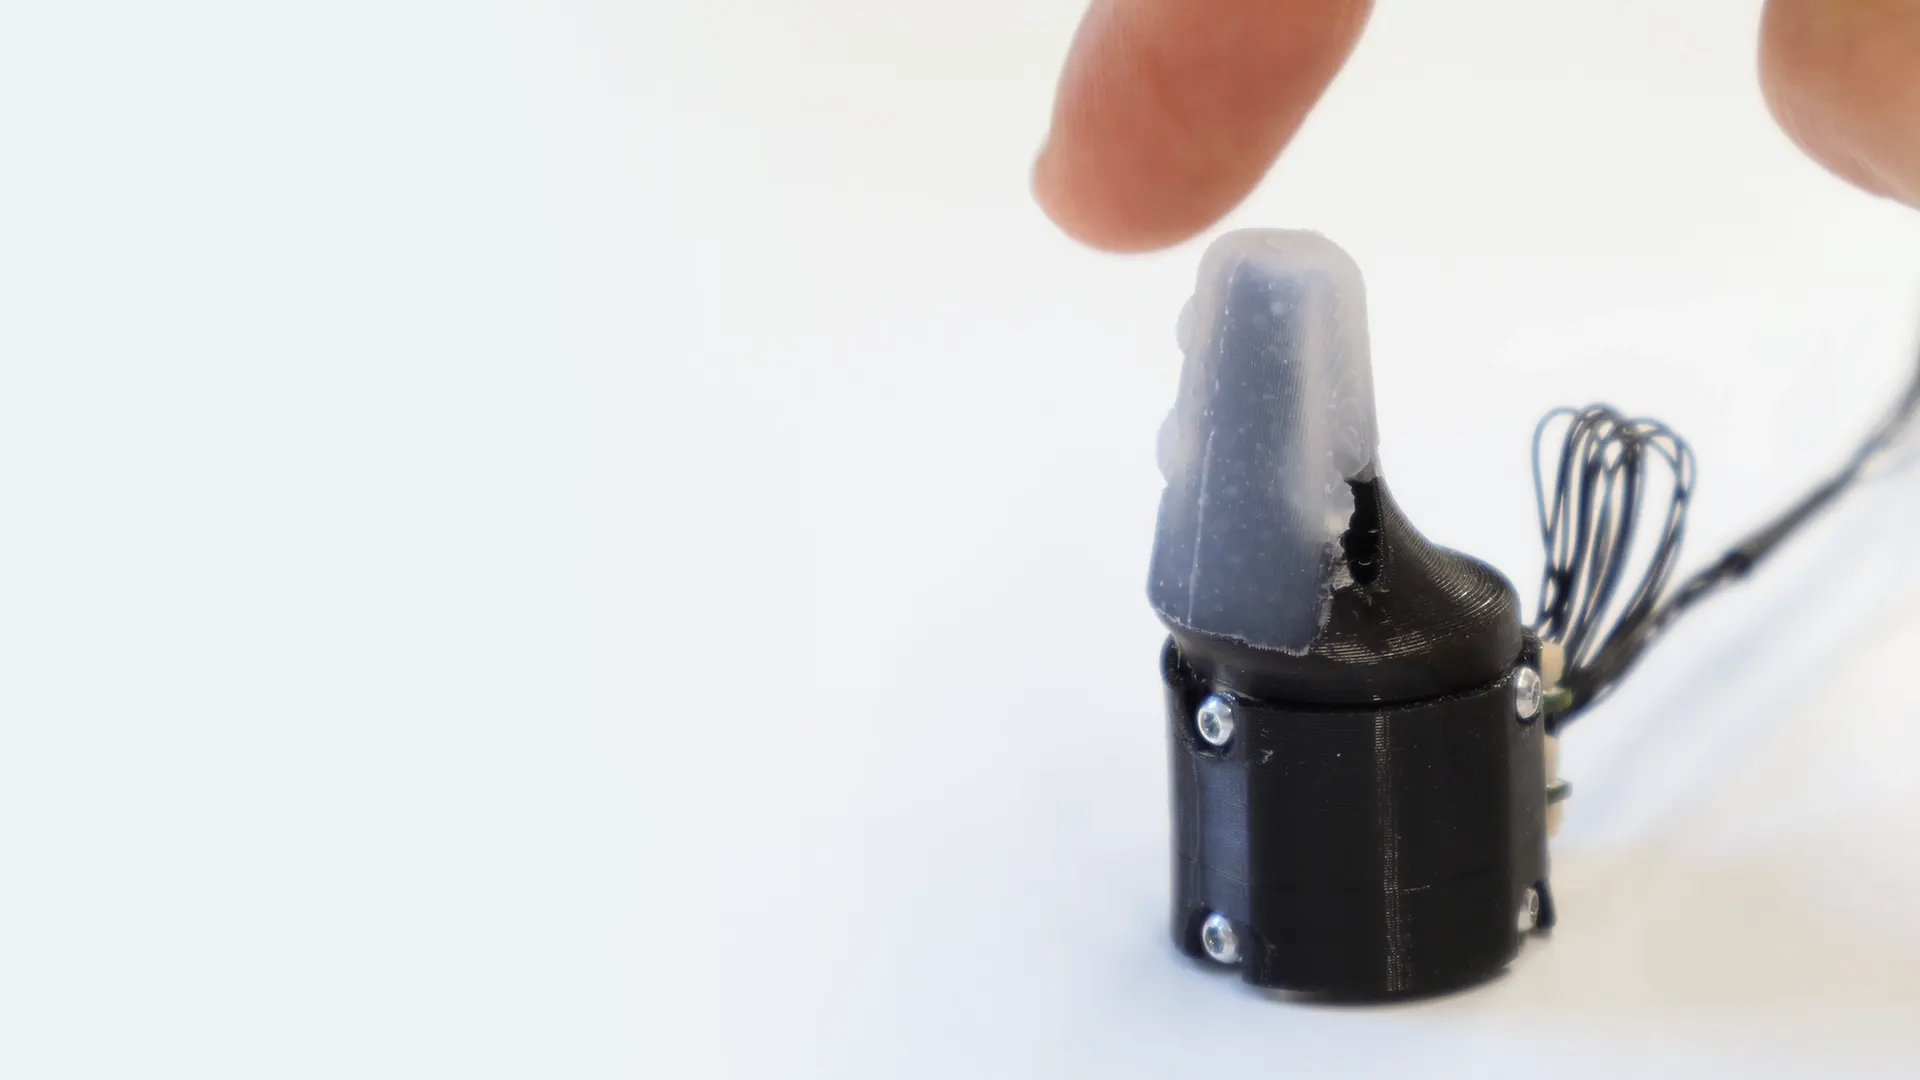
Touch
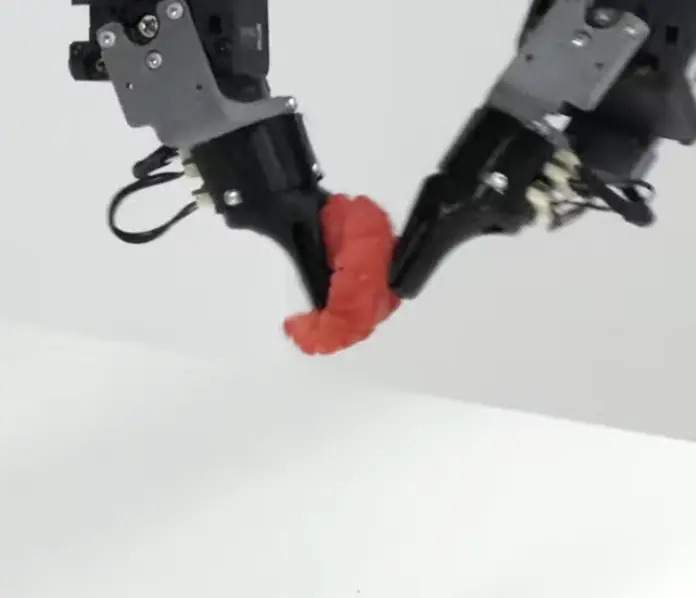
Touch sensing is the cornerstone of fine motor skills. Our sensors use light for touch transduction, with high sensitivity and polling frequency, low latency, simple manufacturing and integration into hands, and low cost. They provide tunable compliance in series with our actuators, simplifying the design of the hand.
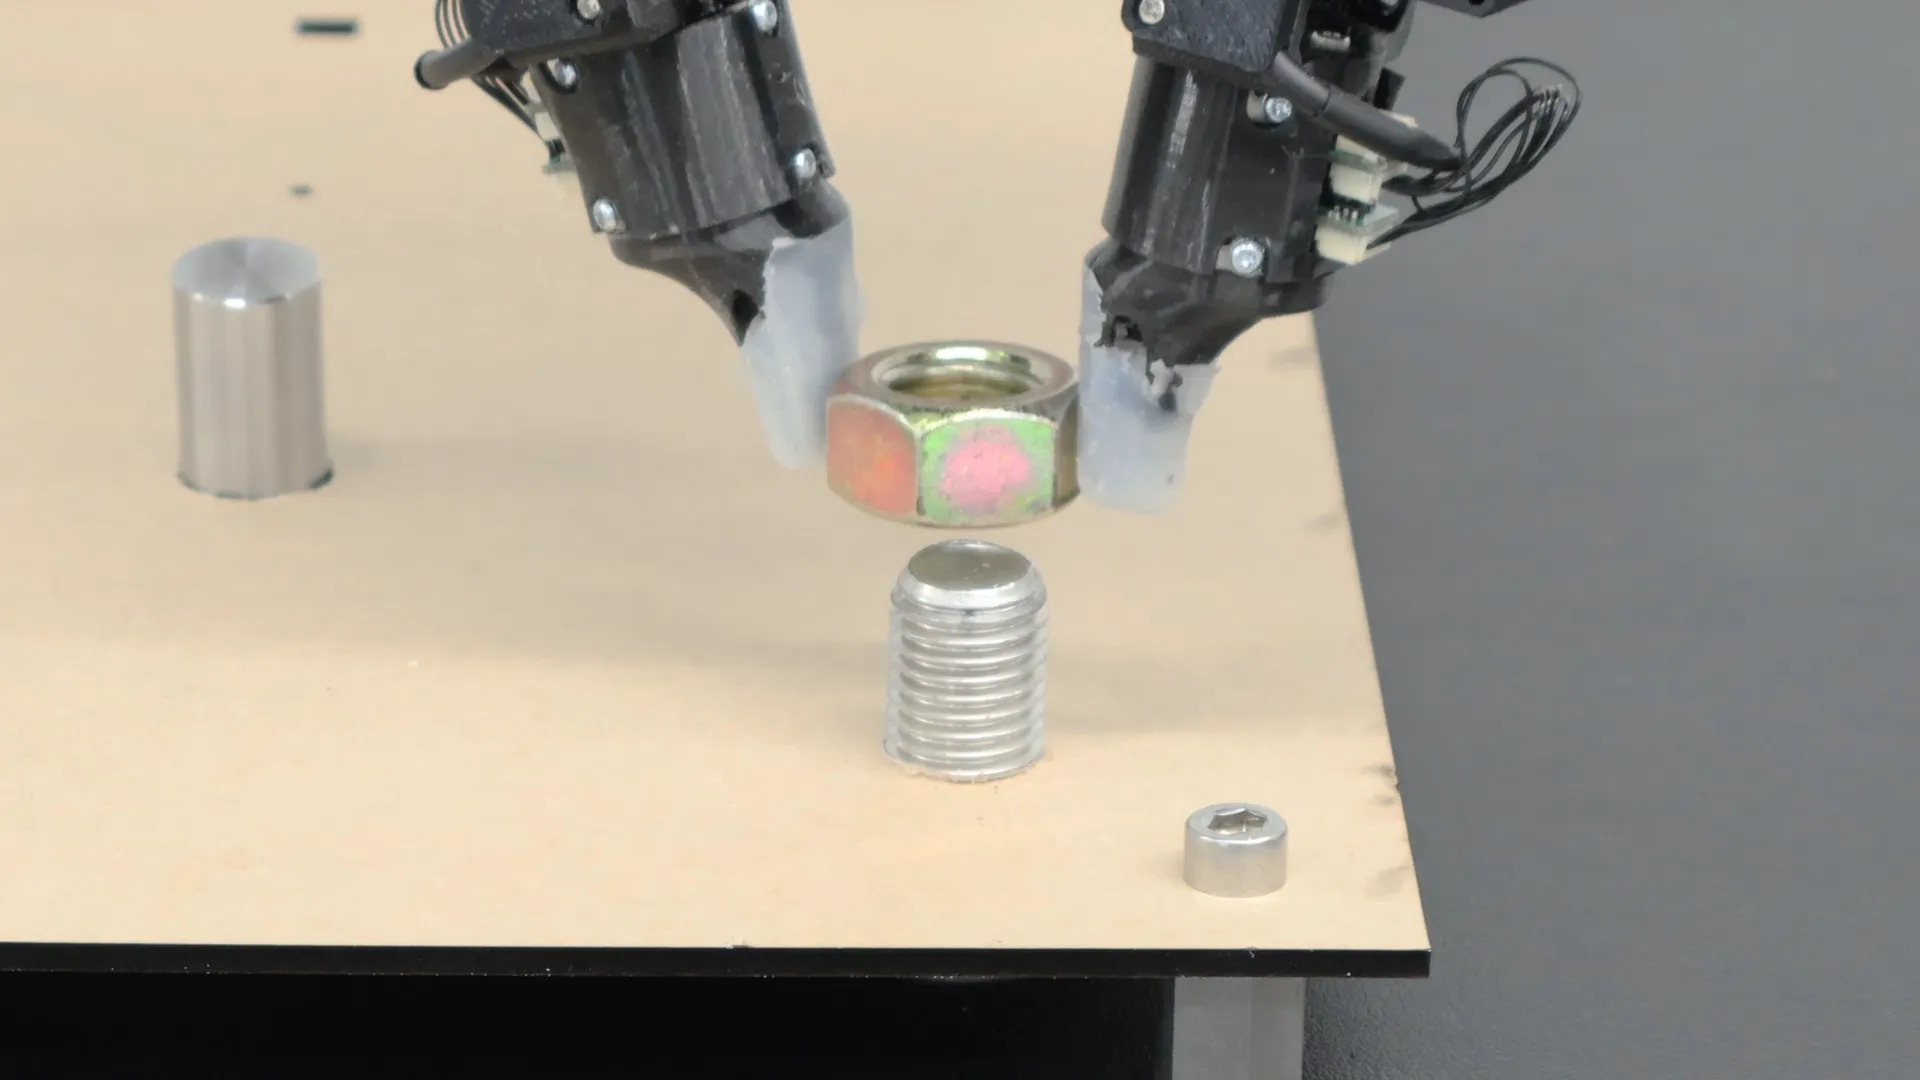
Dexterity
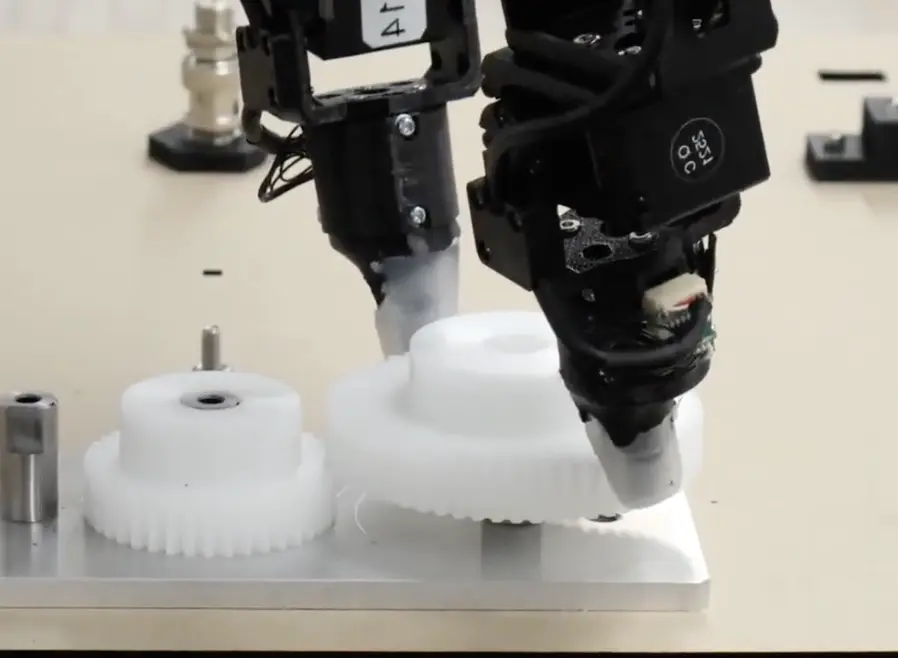
Our motor learning approach combines human fingertip tracking and on-robot learning to train autonomous dexterous policies fusing visual and tactile data for delicate tasks with precise contact and force transmission.
Hardware, sensing and learning combine to form the fine motor skill layer, omnipresent in the real world and needed for most of what we want our economy to build locally, fast and at scale.
We design for the delicate, high-value last mile of skilled manipulation, such as unstructured part sequencing and processing, exacting assemblies and manufacturing, installation and maintenance including disassembly, inspection, reassembly and wiring of electrical or mechanical equipment, and many others.
Documenting the technical details, providing insights into our approach, and highlighting the milestones on the way to autonomous dexterity.
Sep 2026
Aug 2026
Jun 2026
May 2026
Apr 2026
Mar 2026